 Türkçe tr
 English en
 Русский ru
 العربية ar
 Español es
 Português pt
 Azərbaycanca az
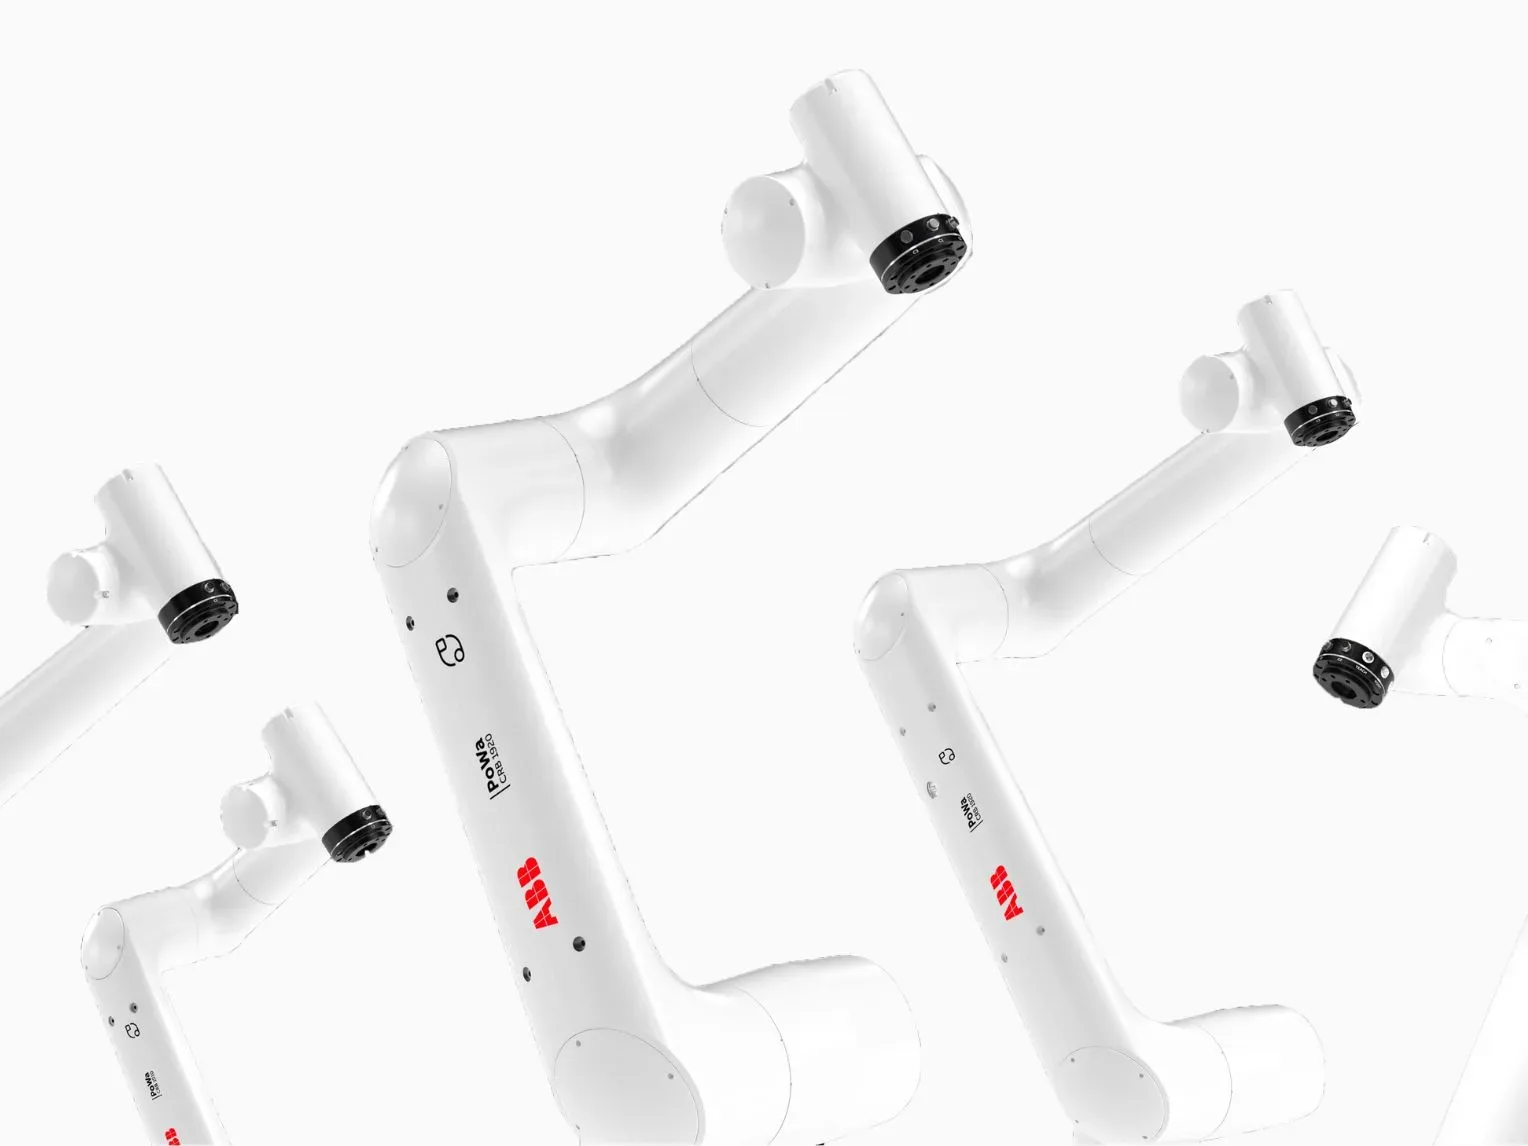
Product image belongs to the manufacturer. Payload and reach values are from the manufacturer's catalogue.
ABB
PoWa 20
Long reach for heavy grippers and palletizing.
- Manufacturer
- ABB
- Series
- PoWa series
- Payload
- 20 kg
- Reach
- 1.67 m (wrist)
The model name is pre-filled in the quote form; just describe your part and application.
What is the PoWa 20 used for?
ABB PoWa is the new series that combines cobot safety with industrial speed: ABB highlights speeds above 5 m/s at rated payload, power and force limiting (PFL) with speed and separation monitoring (SSM), and IP65/IP67 protection.
Typical applications for the PoWa series
- 01Machine tending
- 02Material handling, loading and unloading
- 03Palletising
- 04Welding
- 05Screwdriving and assembly
Model selection weighs part and gripper weight, required reach and cycle-time target together.
We build a working cell around the PoWa 20
Not the robot on its own: we commission it with gripper, fixture, safety and programming, ready for your production.
- Application and risk assessment
- Gripper and fixture selection
- Programming and commissioning
- Operator training and service
For a quote, a part drawing or photo, the part weight and the target cycle time are enough.
Get a quote for the PoWa 20Other models in the series
ABBPoWa series
PoWa 16
The longest-reach model in the family; a large working area and arc welding.
Model detailsABBPoWa series
PoWa 30
The highest-payload model in the family; palletizing and heavy parts.
Model details